CPS: Energy-Aware Dynamic Coverage for Persistent Mobile Observational Networks
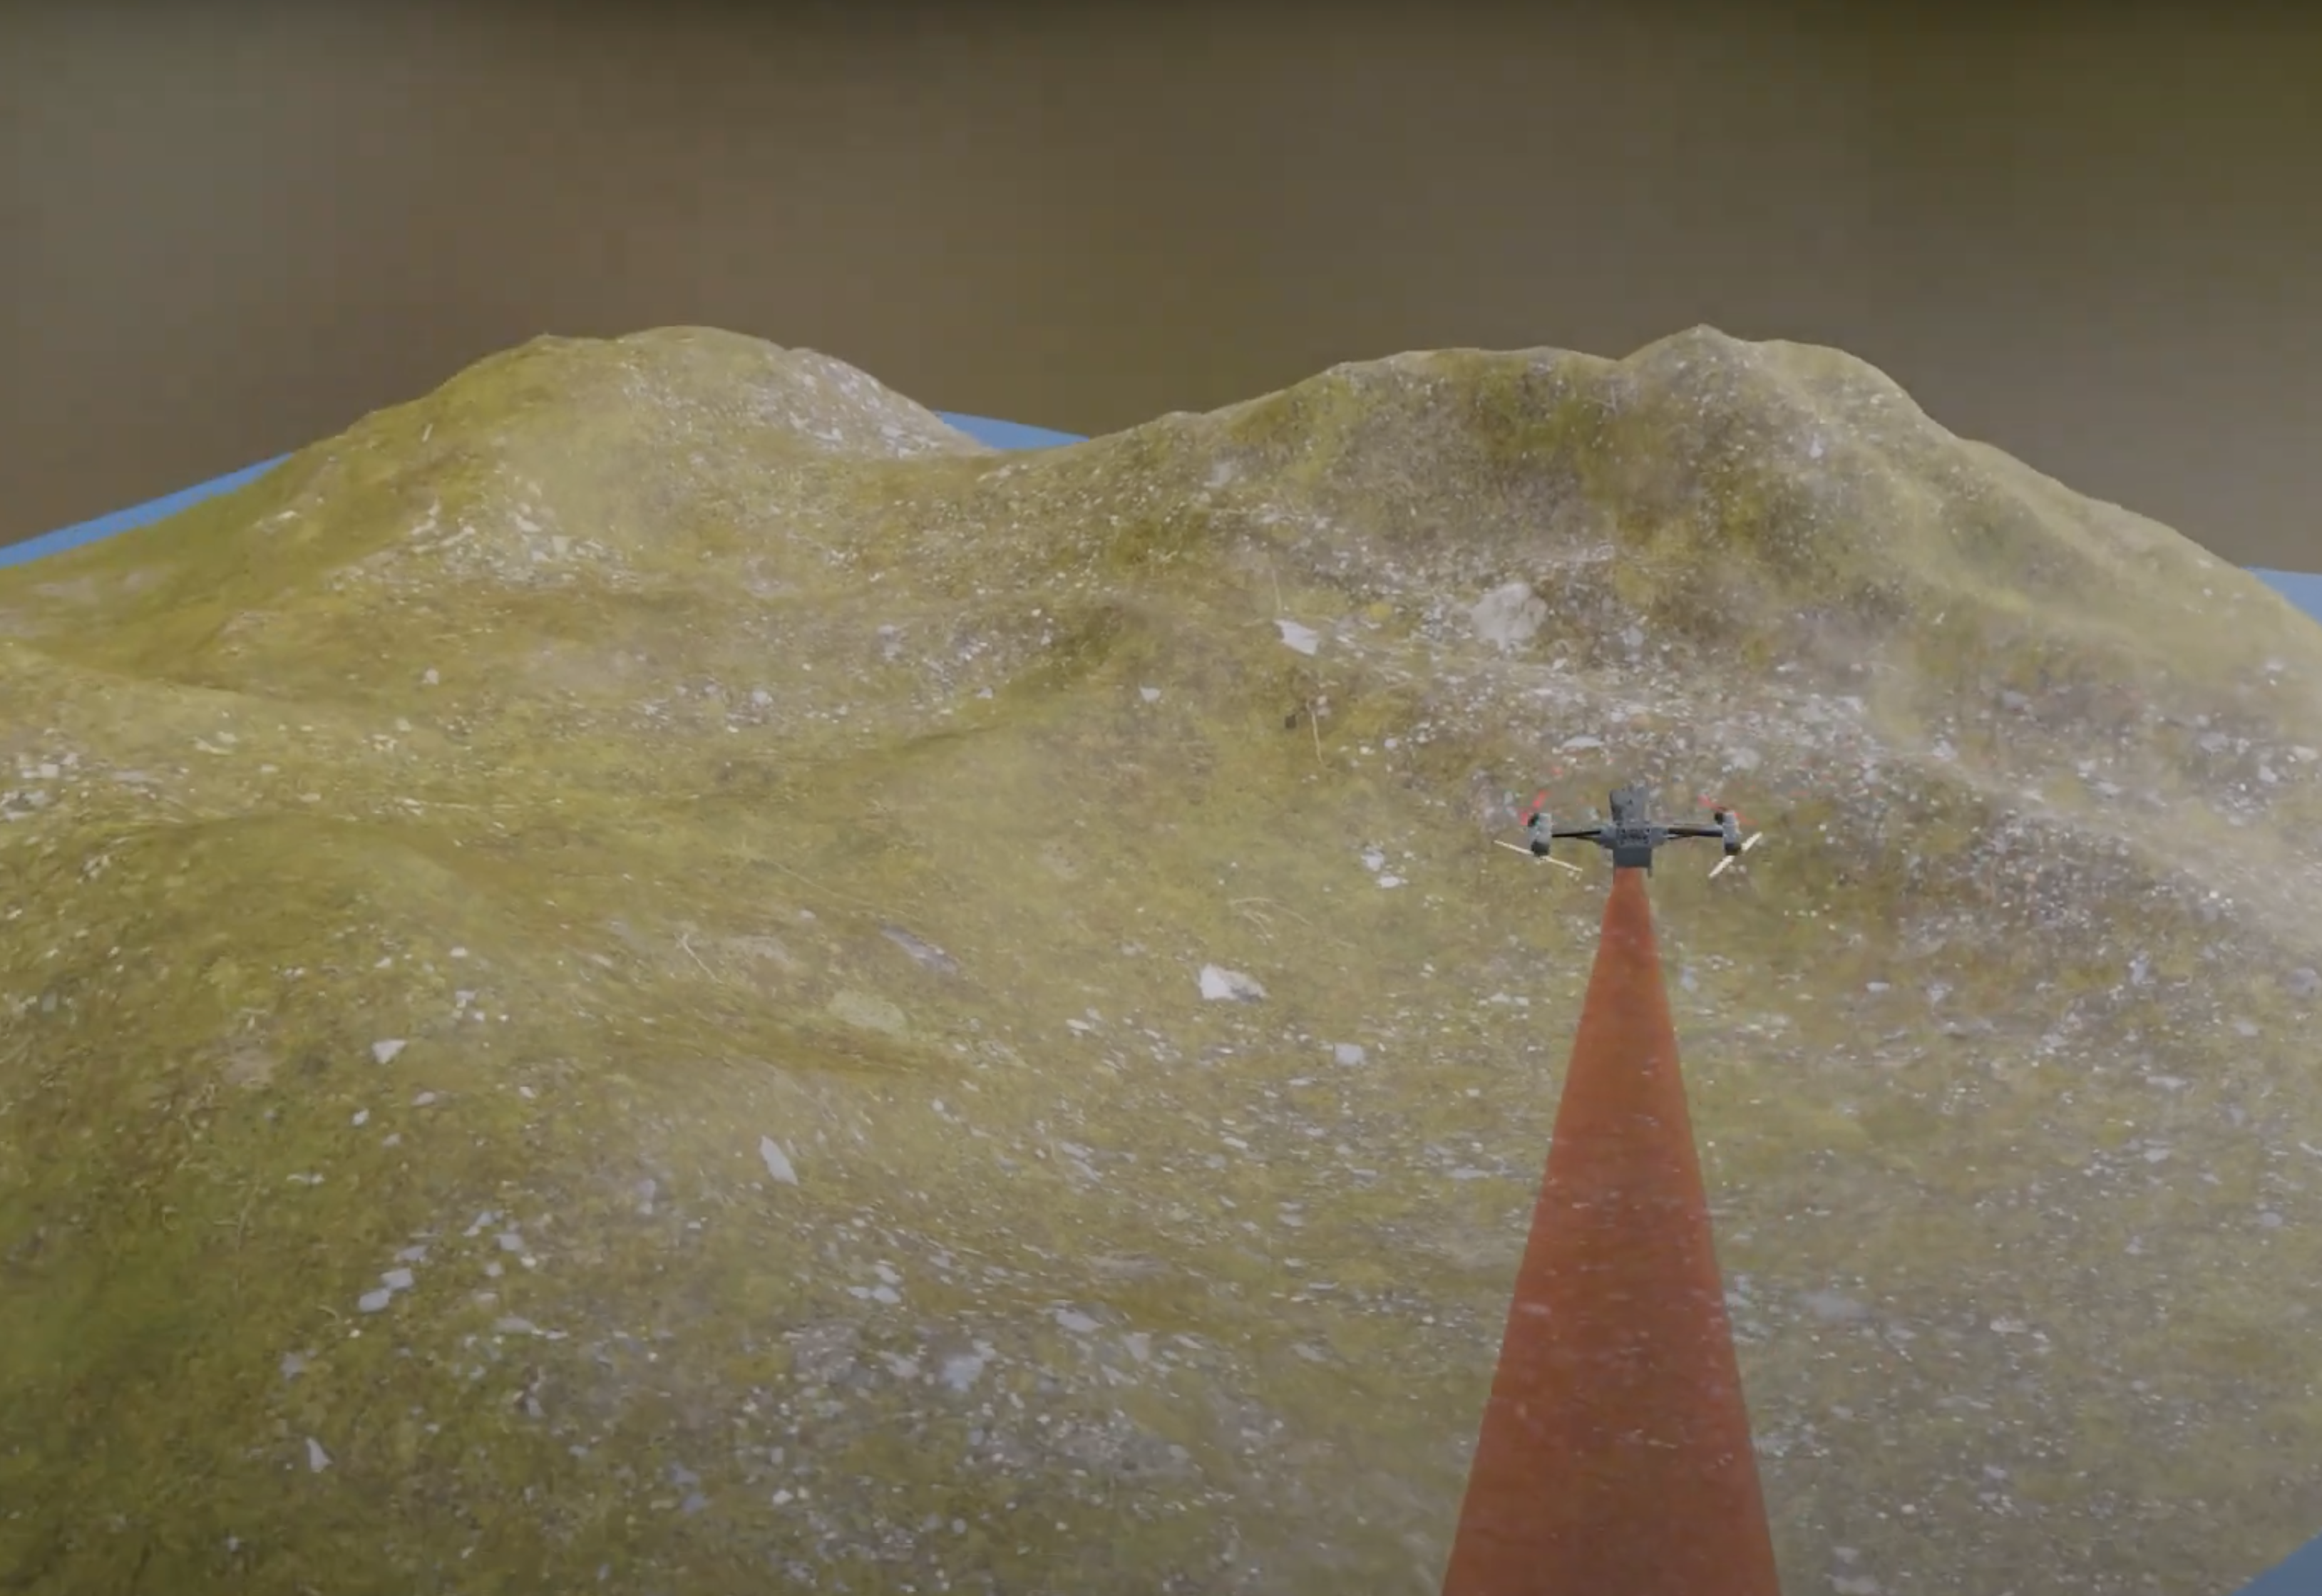
Collaborative Research: CPS: Medium: Enabling Autonomous, Persistent, and Adaptive Mobile Observational Networks Through Energy-Aware Dynamic Coverage (NSF Award #2223845)
Long-duration measurements for weather, climate, and surveillance call for mobile observational networks that can operate persistently with little human intervention. This project develops and validates methods for managing networks made up of a renewably powered host agent and smaller satellite agents that the host deploys and recharges. Energy is treated as renewable but limited in instantaneous power, so the network has to continuously balance energy harvesting against information gathering.
The approach combines:
- a dynamic coverage model that captures how information about the environment decays and is regained (clarity),
- a statistical energy model of harvesting and consumption,
- a multi-level predictive controller, in which the host uses an information value of energy to decide when to explore, recharge, or redeploy satellites.
The methods are validated on UAV networks, on combined solar-powered surface vessel and UAV networks, and in simulation on networks that add undersea gliders. The project also supports internships and K-12 outreach.
People
Principal Investigator
Current Members
Alumni
Papers
- Provably Safe Stein Variational Clarity-Aware Informative PlanningAutonomous robots are increasingly deployed for information-gathering tasks in environments that vary across space and time. Planning informative and safe trajectories in such settings is challenging because information decays when regions are not revisited. Most existing planners model information as static or uniformly decaying, ignoring environments where the decay rate varies spatially; those that model non-uniform decay often overlook how it evolves along the robot's motion, and almost all treat safety as a soft penalty. In this paper, we address these challenges. We model uncertainty in the environment using clarity, a normalized representation of differential entropy from our earlier work that captures how information improves through new measurements and decays over time when regions are not revisited. Building on this, we present Stein Variational Clarity-Aware Informative Planning, a framework that embeds clarity dynamics within trajectory optimization and enforces safety through a low-level filtering mechanism based on our earlier gatekeeper framework for safety verification. The planner performs Bayesian inference-based learning via Stein variational inference, refining a distribution over informative trajectories while filtering each nominal Stein informative trajectory to ensure safety. Hardware experiments and simulations across environments with varying decay rates and obstacles demonstrate consistent safety and reduced information deficits.
- A Formal gatekeeper Framework for Safe Dual Control with Active ExplorationPlanning safe trajectories under model uncertainty is a fundamental challenge. Robust planning ensures safety by considering worst-case realizations, yet ignores uncertainty reduction and leads to overly conservative behavior. Actively reducing uncertainty on-the-fly during a nominal mission defines the dual control problem. Most approaches address this by adding a weighted exploration term to the cost, tuned to trade off the nominal objective and uncertainty reduction, but without formal consideration of when exploration is beneficial. Moreover, safety is enforced in some methods but not in others. We propose a framework that integrates robust planning with active exploration under formal guarantees as follows: The key innovation and contribution is that exploration is pursued only when it provides a verifiable improvement without compromising safety. To achieve this, we utilize our earlier work on gatekeeper as an architecture for safety verification, and extend it so that it generates both safe and informative trajectories that reduce uncertainty and the cost of the mission, or keep it within a user-defined budget. The methodology is evaluated via simulation case studies on the online dual control of a quadrotor under parametric uncertainty.
- Multi-Robot Allocation for Information Gathering in Non-Uniform Spatiotemporal EnvironmentsAutonomous robots are increasingly deployed to estimate spatiotemporal fields (e.g., wind, temperature, gas concentration) that vary across space and time. We consider environments divided into non-overlapping regions with distinct spatial and temporal dynamics, termed non-uniform spatiotemporal environments. Gaussian Processes (GPs) can be used to estimate these fields. The GP model depends on a kernel that encodes how the field co-varies in space and time, with its spatial and temporal lengthscales defining the correlation. Hence, when these lengthscales are incorrect or do not correspond to the actual field, the estimates of uncertainty can be highly inaccurate. Existing GP methods often assume one global lengthscale or update only periodically; some allow spatial variation but ignore temporal changes. To address these limitations, we propose a two-phase framework for multi-robot field estimation. Phase 1 uses a variogram-driven planner to learn region-specific spatial lengthscales. Phase 2 employs an allocation strategy that reassigns robots based on the current uncertainty, and updates sampling as temporal lengthscales are refined. For encoding uncertainty, we utilize clarity, an information metric from our earlier work. We evaluate the proposed method across diverse environments and provide convergence analysis for spatial lengthscale estimation, along with dynamic regret bounds quantifying the gap to the oracle's allocation sequence
- Adaptive Ergodic Search with Energy-Aware Scheduling for Persistent Multi-Robot MissionsAutonomous robots are increasingly deployed for long-term information-gathering tasks, which pose two key challenges: planning informative trajectories in environments that evolve across space and time, and ensuring persistent operation under energy constraints. This paper presents a unified framework, mEclares, that addresses both challenges through adaptive ergodic search and energy-aware scheduling in multi-robot systems. Our contributions are two-fold: (1) we model real-world variability using stochastic spatiotemporal environments, where the underlying information evolves unpredictably due to process uncertainty. To guide exploration, we construct a target information spatial distribution (TISD) based on clarity, a metric that captures the decay of information in the absence of observations and highlights regions of high uncertainty; and (2) we introduce Robustmesch (Rmesch), an online scheduling method that enables persistent operation by coordinating rechargeable robots sharing a single mobile charging station. Unlike prior work, our approach avoids reliance on preplanned schedules, static or dedicated charging stations, and simplified robot dynamics. Instead, the scheduler supports general nonlinear models, accounts for uncertainty in the estimated position of the charging station, and handles central node failures. The proposed framework is validated through real-world hardware experiments, and feasibility guarantees are provided under specific assumptions.
- meSch: Multi-Agent Energy-Aware Scheduling for Task PersistenceThis paper develops a scheduling protocol for a team of autonomous robots that operate on long-term persistent tasks. The proposed framework, called meSch, accounts for the limited battery capacity of the robots and ensures that the robots return to charge their batteries one at a time at the single charging station. The protocol is applicable to general nonlinear robot models under certain assumptions, does not require robots to be deployed at different times, and can handle robots with different discharge rates. We further consider the case when the charging station is mobile and its state information is subject to uncertainty. The feasibility of the algorithm in terms of ensuring persistent charging is given under certain assumptions, while the efficacy of meSch is validated through simulation and hardware experiments.
- Multi-Agent Clarity-Aware Dynamic Coverage with Gaussian ProcessesThis paper presents two algorithms for multi-agent dynamic coverage in spatiotemporal environments, where the coverage algorithms are informed by the method of data assimilation. In particular, we show that by explicitly modeling the environment using a Gaussian Process (GP) model, and considering the sensing capabilities and the dynamics of a team of robots, we can design an estimation algorithm and multi-agent coverage controller that explores and estimates the state of the spatiotemporal environment. The uncertainty of the estimate is quantified using clarity, an information-theoretic metric, where higher clarity corresponds to lower uncertainty. By exploiting the relationship between GPs and Stochastic Differential Equations (SDEs) we quantify the increase in clarity of the estimated state at any position due to a measurement taken from any other position. We use this relationship to design two new coverage controllers, both of which scale well with the number of agents exploring the domain, assuming the robots can share the map of the clarity over the spatial domain via communication. We demonstrate the algorithms through a realistic simulation of a team of robots collecting wind data over a region in Austria.
- Eclares: Energy-Aware Clarity-Driven Ergodic SearchPlanning informative trajectories while considering the spatial distribution of the information over the environment, as well as constraints such as the robot’s limited battery capacity, makes the long-time horizon persistent coverage problem complex. Ergodic search methods consider the spatial distribution of environmental information while optimizing robot trajectories; however, current methods lack the ability to construct the target information spatial distribution for environments that vary stochastically across space and time. Moreover, current coverage methods dealing with battery capacity constraints either assume simple robot and battery models or are computationally expensive. To address these problems, we propose a framework called Eclares, in which our contribution is two-fold. 1) First, we propose a method to construct the target information spatial distribution for ergodic trajectory optimization using clarity, an information measure bounded between [0, 1]. The clarity dynamics allow us to capture information decay due to a lack of measurements and to quantify the maximum attainable information in stochastic spatiotemporal environments. 2) Second, instead of directly tracking the ergodic trajectory, we introduce the energy-aware (eware) filter, which iteratively validates the ergodic trajectory to ensure that the robot has enough energy to return to the charging station when needed. The proposed eware filter is applicable to nonlinear robot models and is computationally lightweight. We demonstrate the working of the framework through a simulation case study.
@inproceedings{naveed2024eclares,
  title={Eclares: Energy-aware clarity-driven ergodic search},
  author={Naveed, Kaleb Ben and Agrawal, Devansh and Vermillion, Christopher and Panagou, Dimitra},
  booktitle={2024 IEEE International Conference on Robotics and Automation (ICRA)},
  pages={14326--14332},
  year={2024},
  organization={IEEE}
}