Projects
The projects listed below are the funded projects that have been active since 2025.
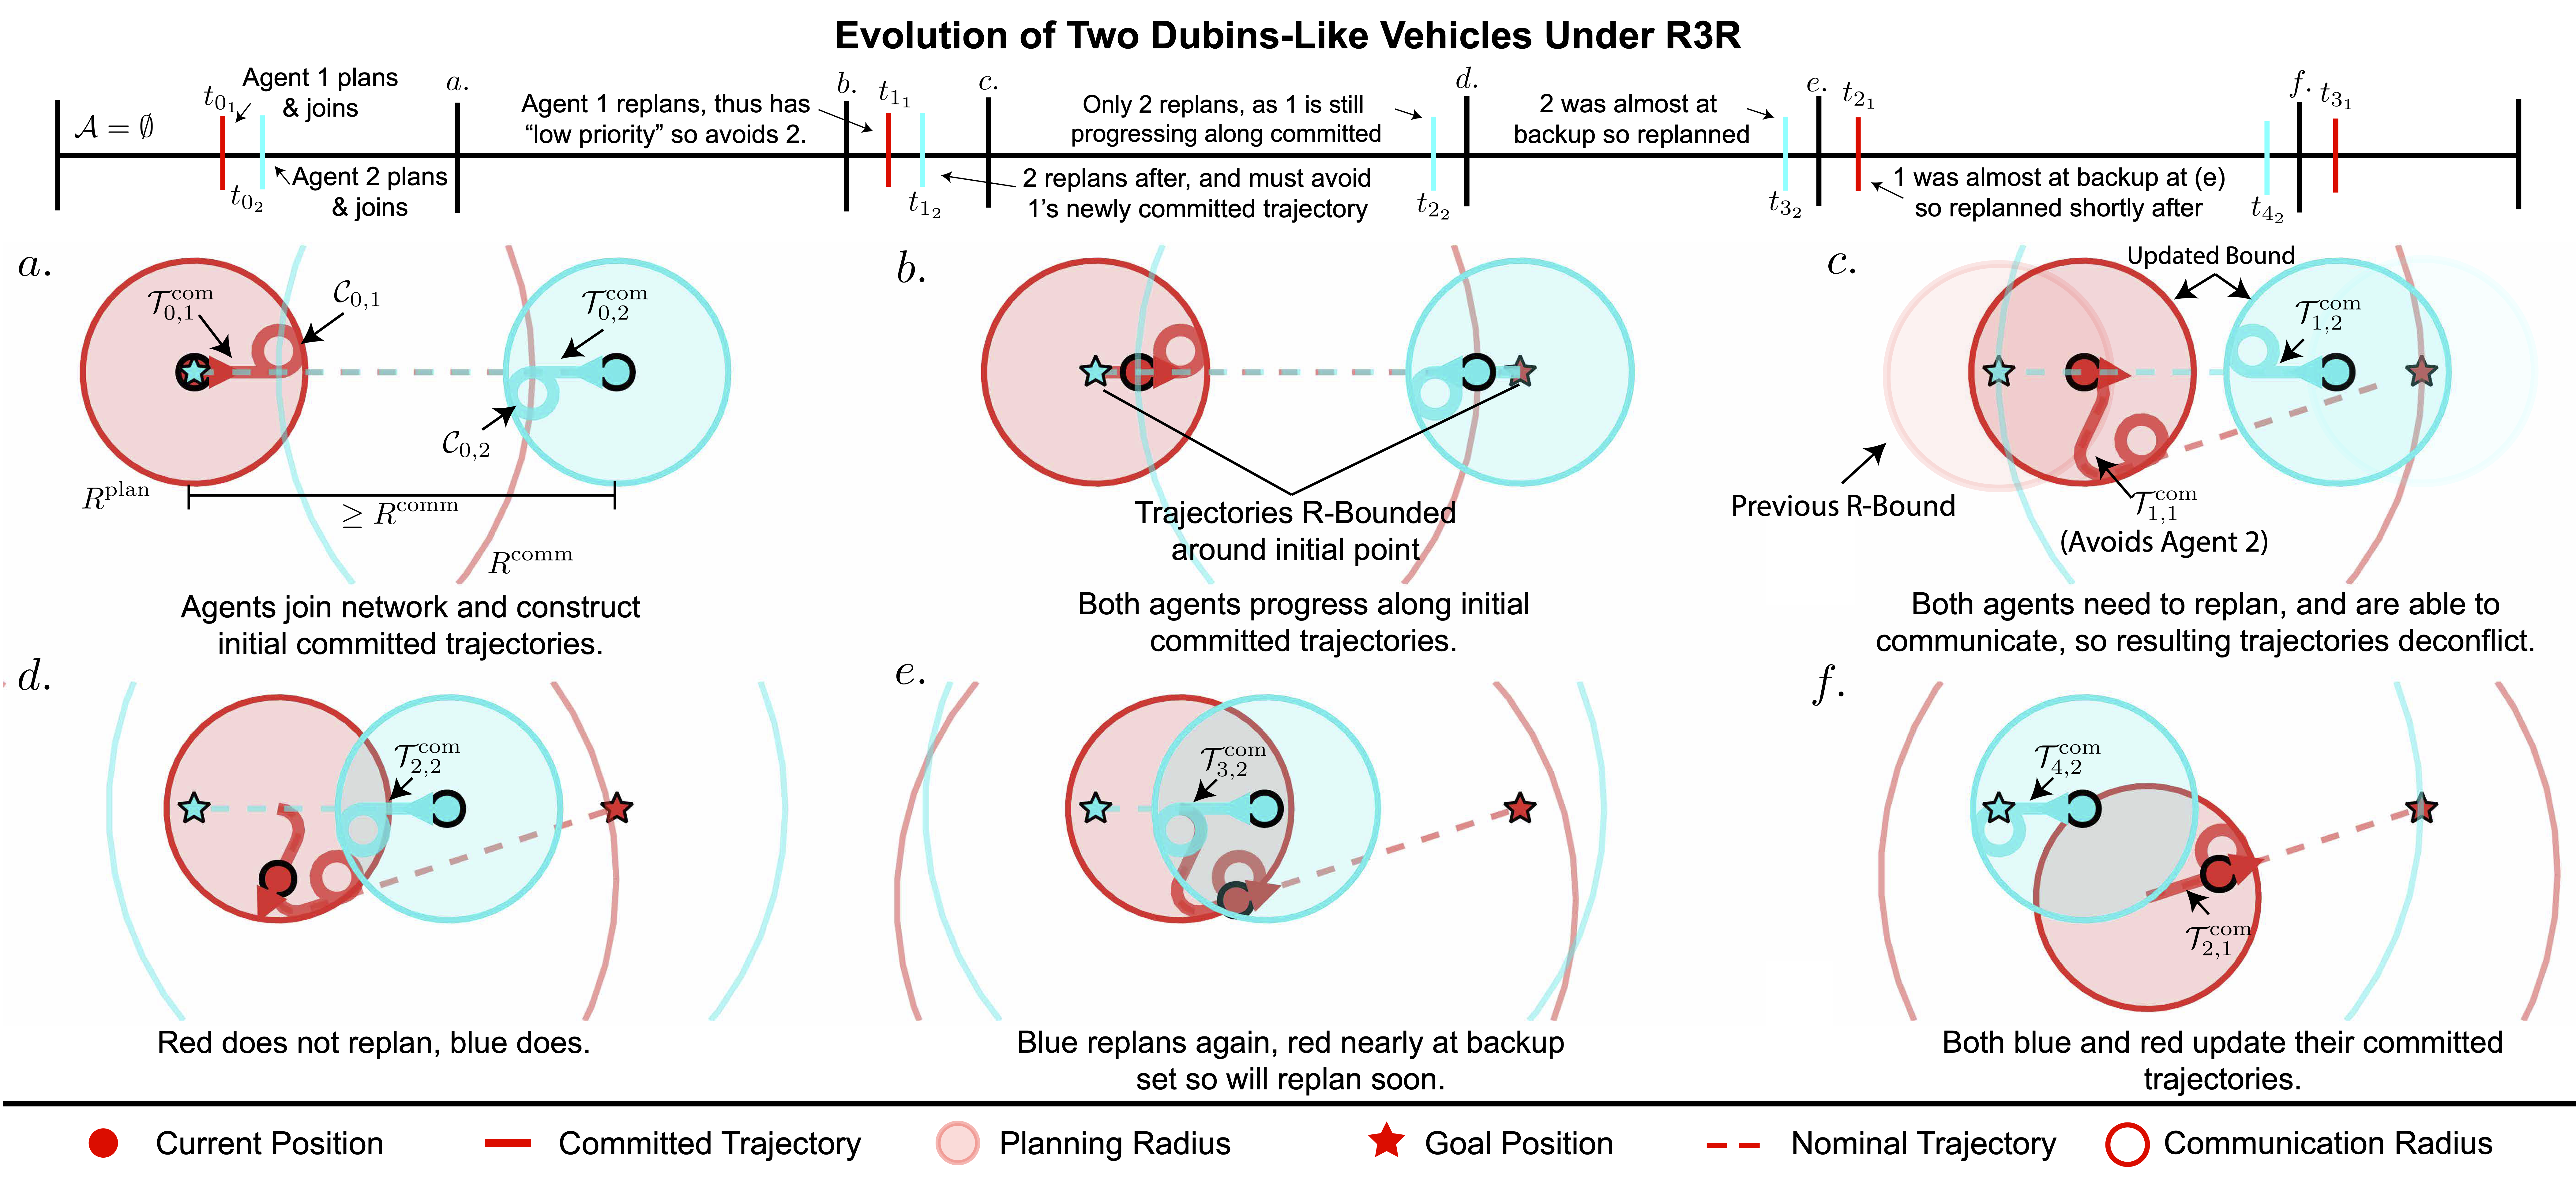
CAAMS: Center for Autonomous Air Mobility and Sensing
Safety-critical planning, verification, and learning-enabled control for trusted autonomous air mobility and multi-agent systems under uncertainty.
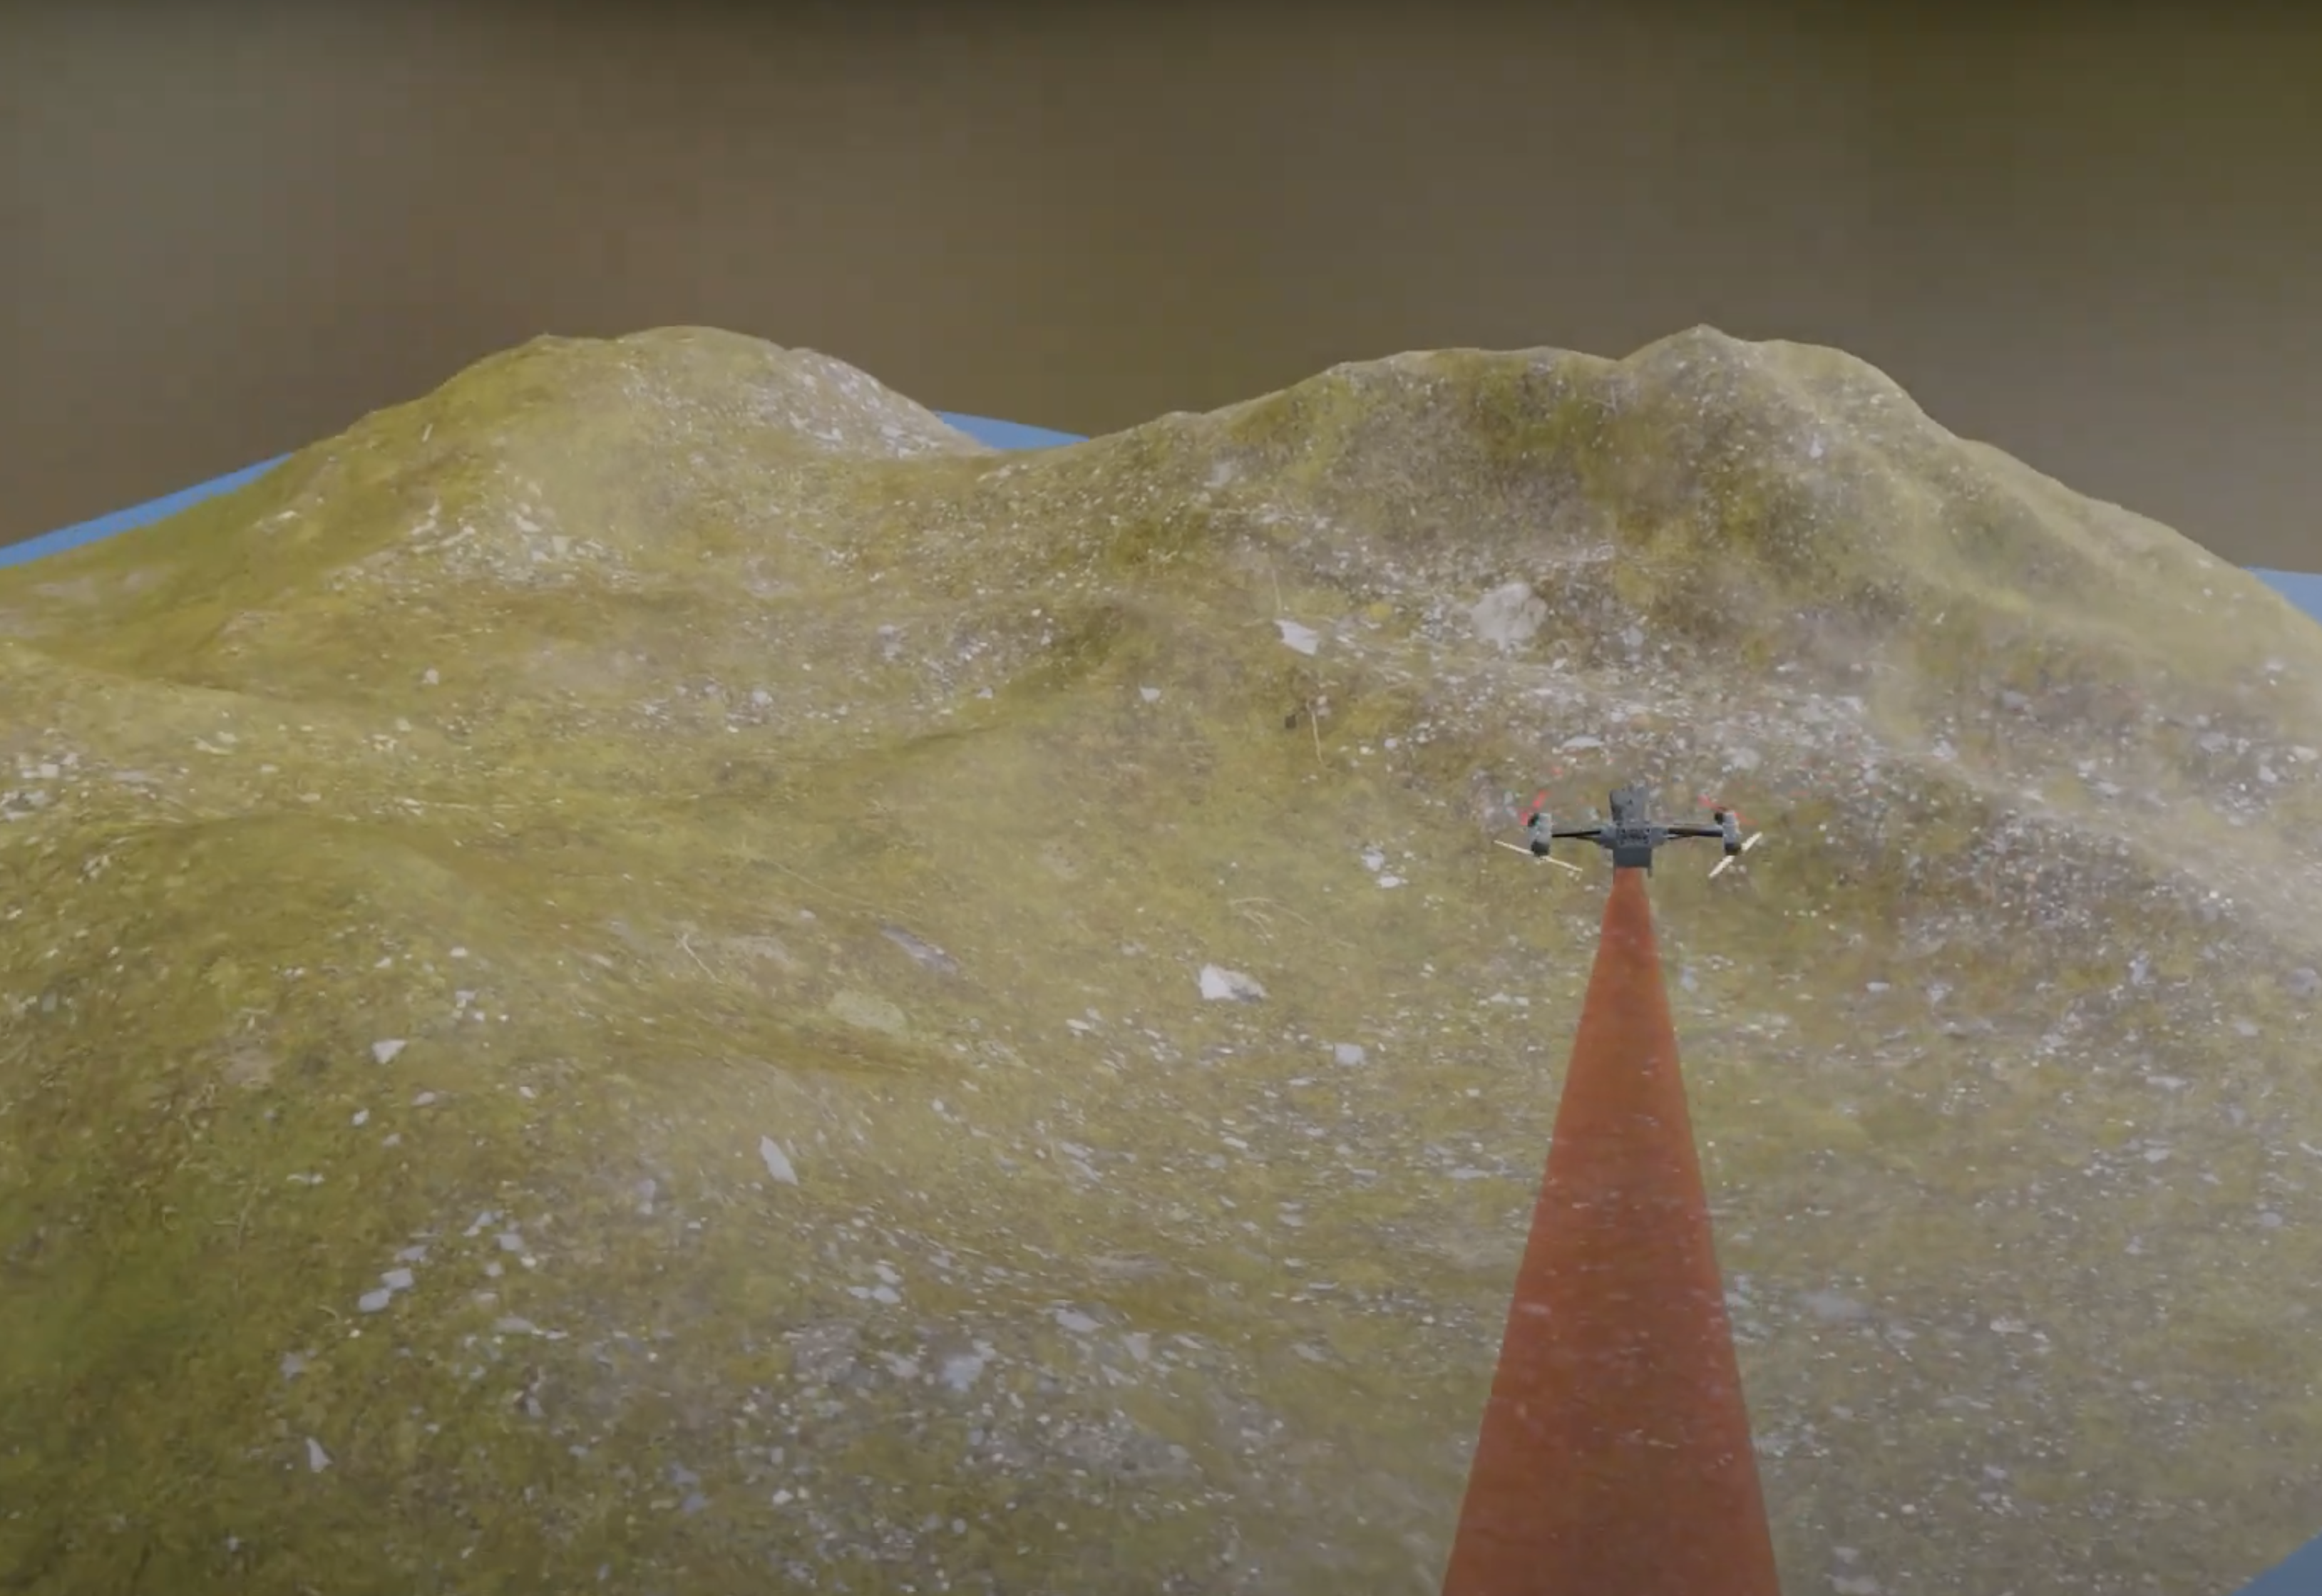
CPS: Energy-Aware Dynamic Coverage for Persistent Mobile Observational Networks
Autonomous, persistent, and adaptive mobile observational networks that balance energy harvesting against information gathering.
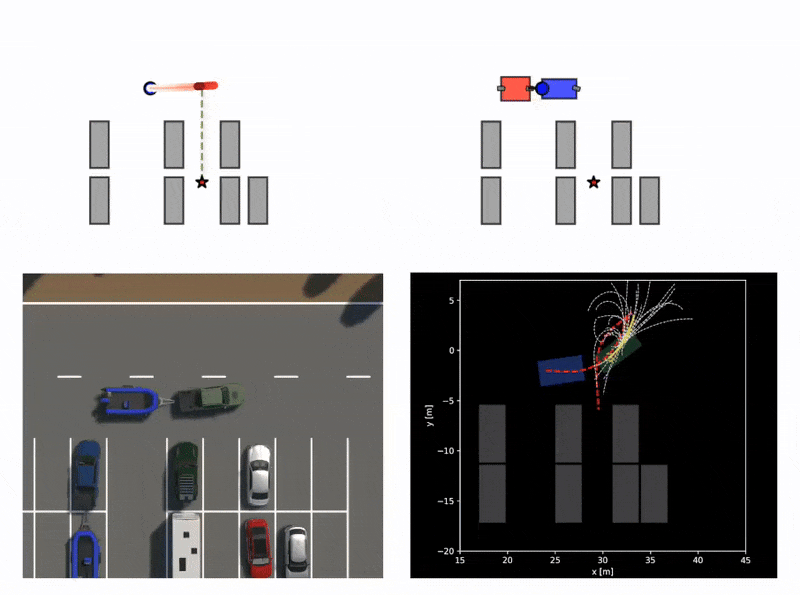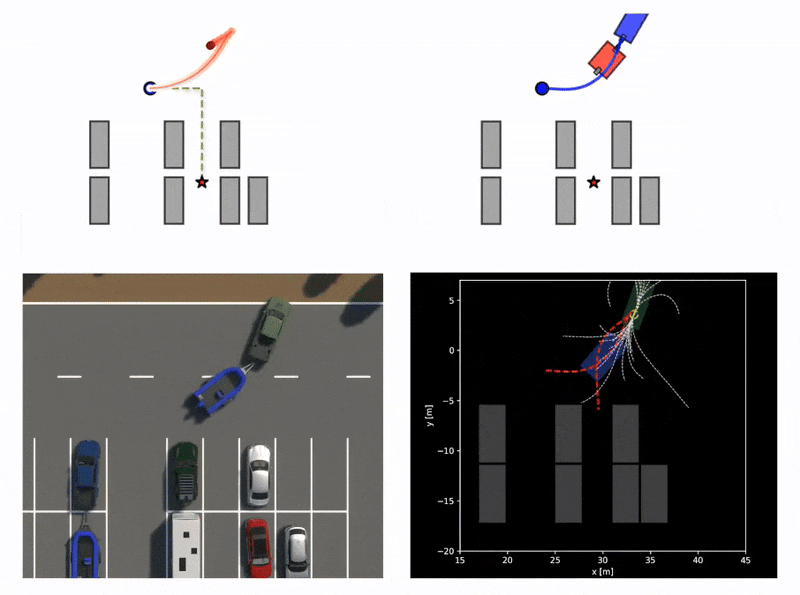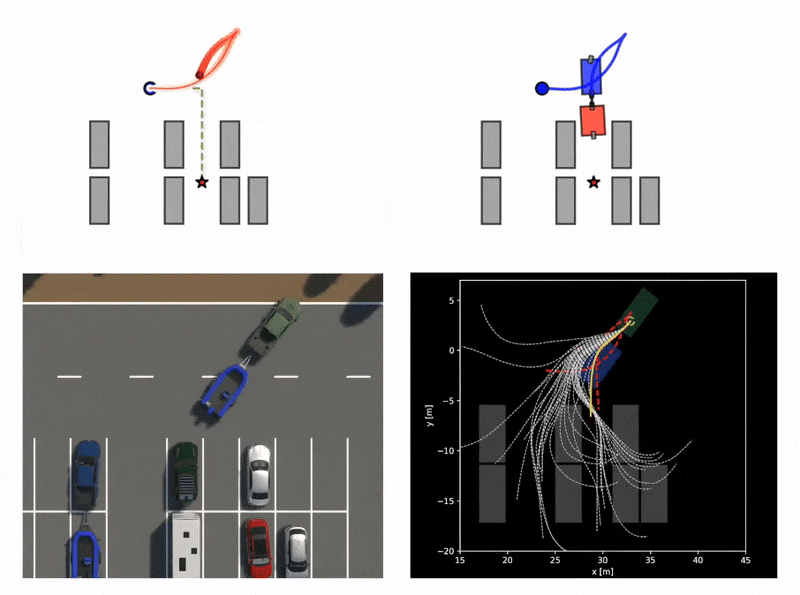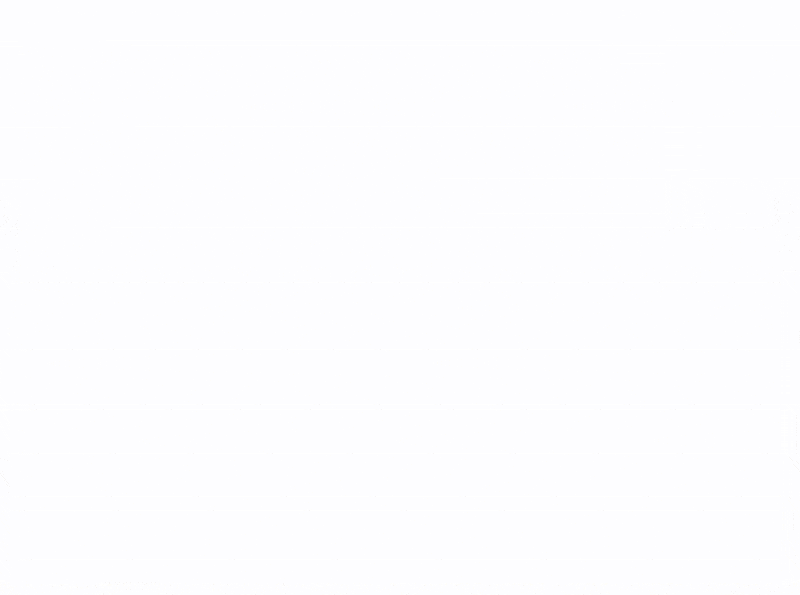
TRINA: Safety-Critical Autonomy for Future Mobility
Safe and reliable planning, control, and learning for autonomous mobility and robotic systems operating in complex and uncertain environments.
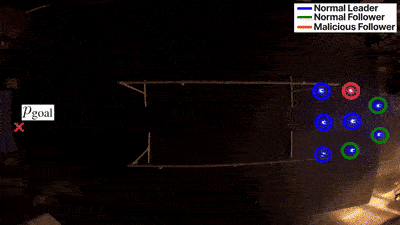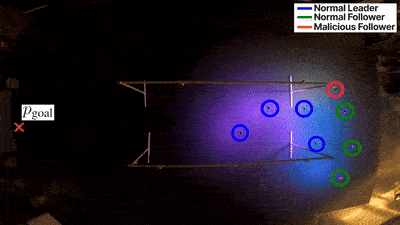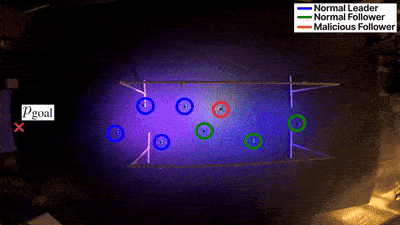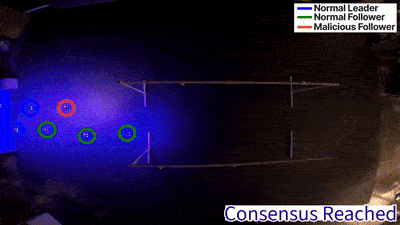
AFOSR: Networked Adversarially-Resilient Reconfigurable Operations in Obstacle Worlds
Safe planning and attack-tolerant control and estimation for multi-robot networks that must stay resilient to adversaries while operating in confined, obstacle-rich environments.
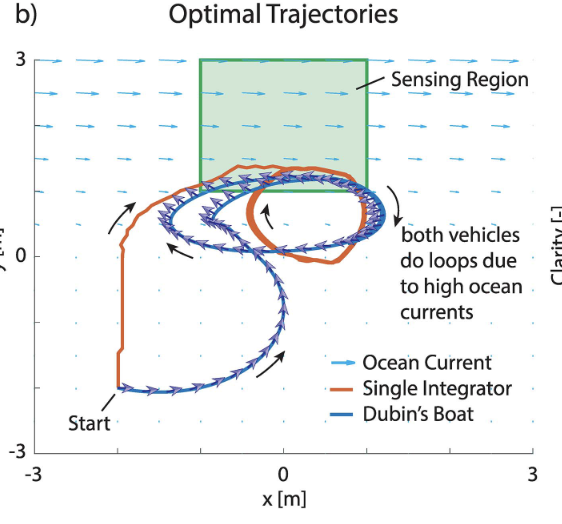
NSF CAREER: Perceivability: Enabling Safe and Secure Autonomy via Synergistic Control, Observation and Learning
Foundations of perceivability: when and how an autonomous system can safely build knowledge of an unknown, uncertain, dynamic environment under physical and informational constraints.