Multi-Objective Kinodynamic Planning in Stochastic Environments
Code
Abstract
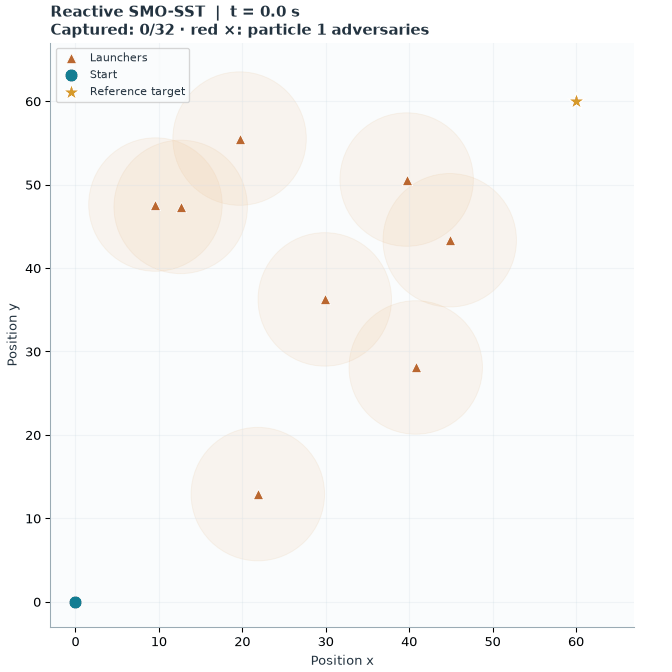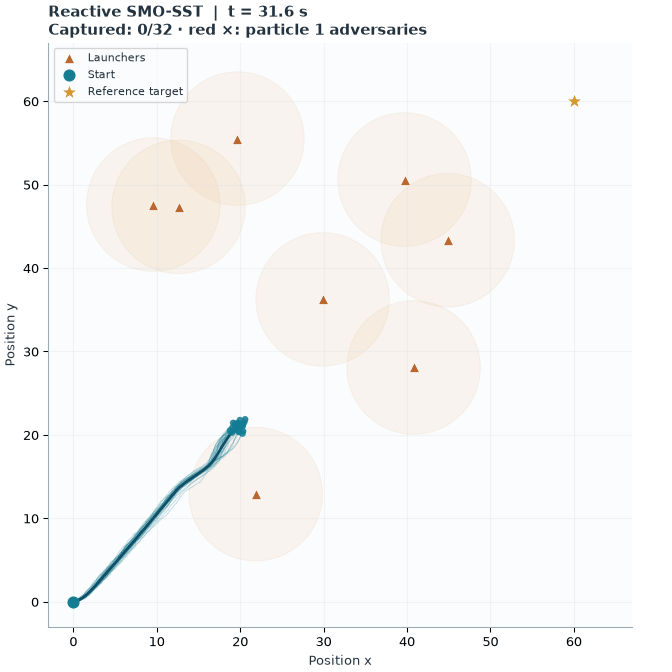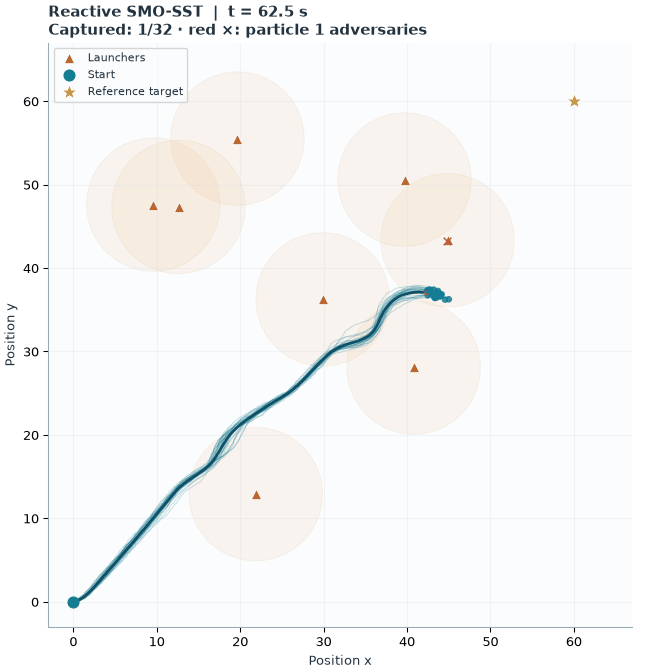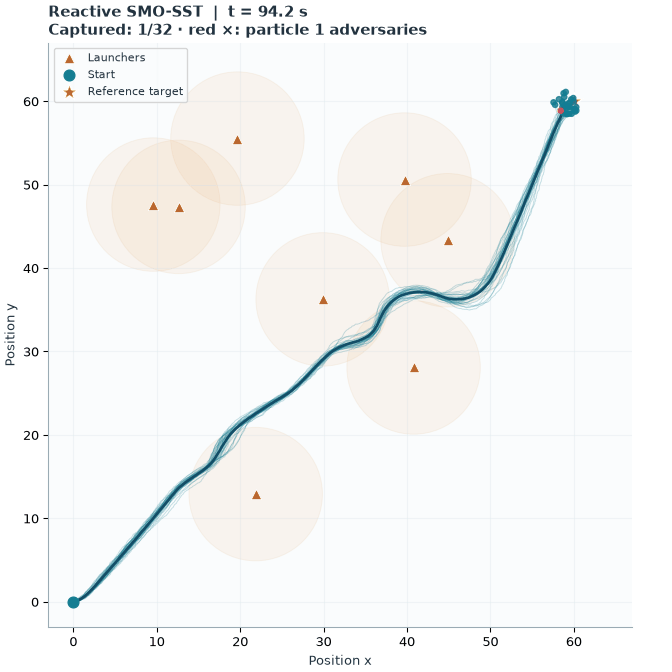
This paper addresses kinodynamic planning for stochastic nonlinear systems subject to non-Gaussian disturbances in reactive stochastic hybrid environments. Conventional chance-constrained formulations require a prescribed risk threshold. We reformulate the problem as a multi-objective optimization in which risk and expected cost are jointly minimized. To efficiently approximate the Pareto front of solutions to the proposed problem, we introduce Stochastic Multi-Objective Stable Sparse RRT (SMO-SST), which extends the sparsification approach of Stable Sparse RRT (SST) to the proposed stochastic multi-objective problem. We prove the proposed algorithm to be asymptotically near-optimal with respect to the risk-cost Pareto front, and provide explicit bounds on approximation error. In wall-clock-matched trials, the proposed algorithm outperformed non-pruning ablations, showcasing the efficacy of the proposed pruning mechanism. These results provide a principled framework for exploring risk-performance tradeoffs in nonlinear, non-Gaussian, reactive environments.