Trajectory Planning for Safe Dual Control with Active Exploration
Trajectory Planning for Safe Dual Control with Active Exploration
Under Review, 2026
Funded by:
CPS
Code
Abstract
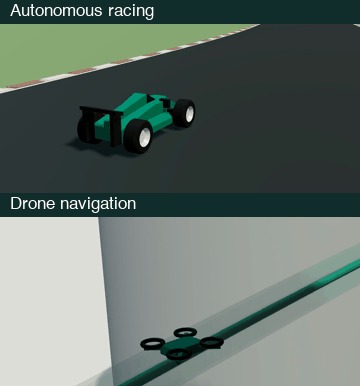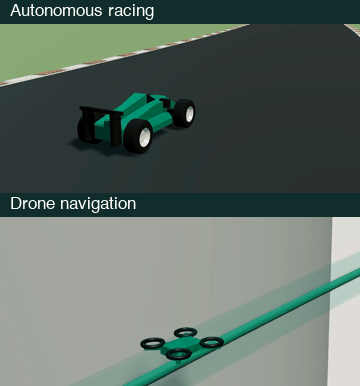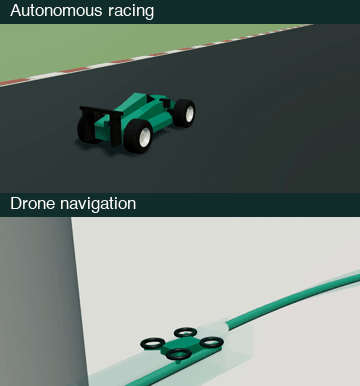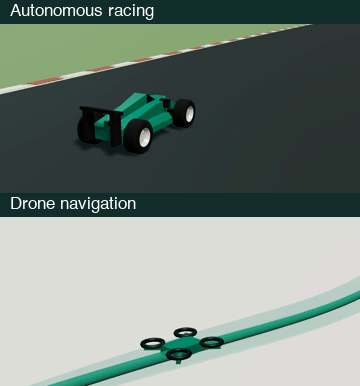
Dual-gatekeeper plans trajectories that reduce model uncertainty during a mission while respecting safety constraints and an explicit exploration budget. The framework verifies conservative and informative candidate trajectories before execution, selects feasible informative motion, and updates its model uncertainty from new measurements. Deterministic and probabilistic safety implementations are demonstrated through quadrotor navigation and autonomous car racing under uncertain dynamics.