Disturbance-Aware Informative Planning in Spatiotemporal Environments
Disturbance-Aware Informative Planning in Spatiotemporal Environments
Under Review, 2026
Code
Abstract
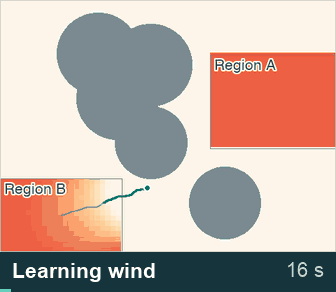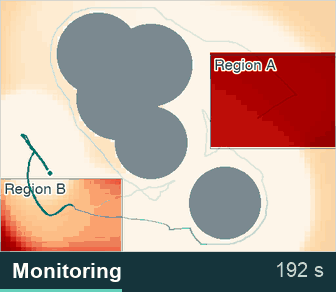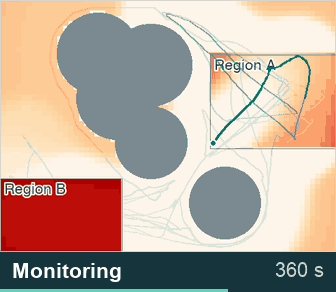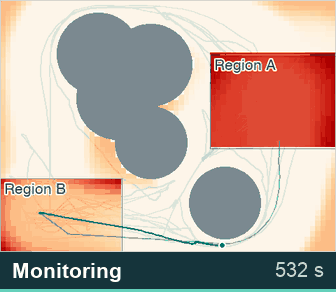
A robot monitoring a changing environment must revisit locations as its measurements become stale. Wind can slow the robot or push it off course. The planner first identifies routes to locations that need fresh measurements and samples wind where its uncertainty matters for those routes. It then uses the learned wind field to predict how much information the robot can collect along each trajectory. In four simulations, targeted sampling cut the time spent learning disturbances by 25.0–52.3% compared with sampling across the whole environment.