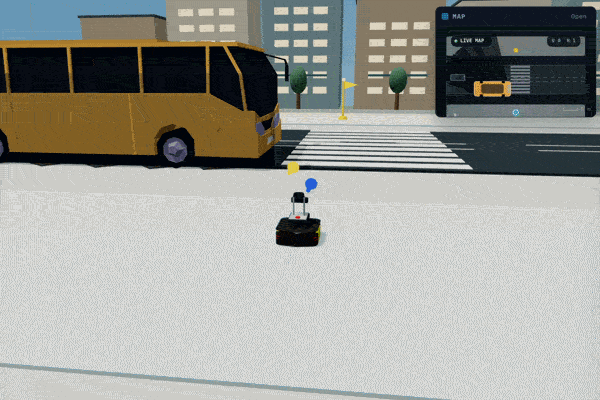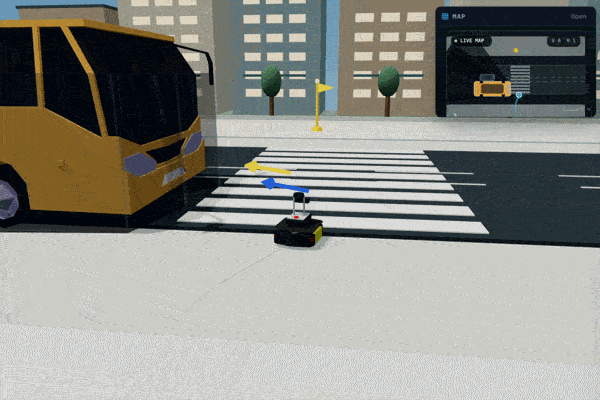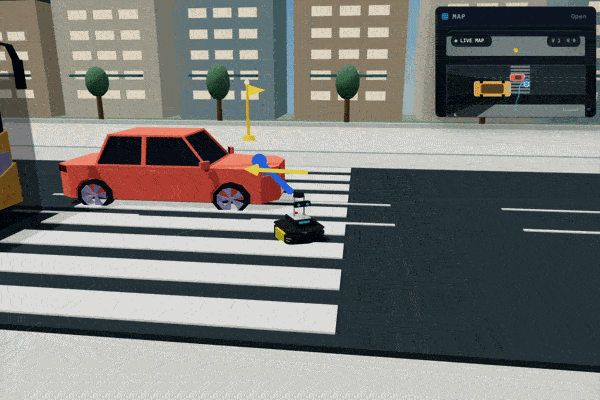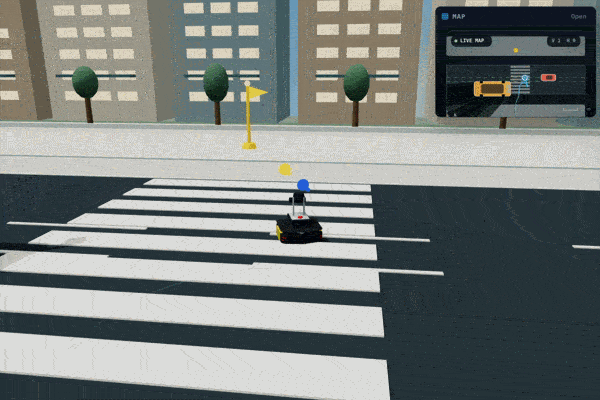
OcclusionCBF
Explore how a backup safety filter responds to moving obstacles hidden by occlusions.
Explore our research through interactive simulations. Open a demo to try it in your browser, or follow the related paper for the method and its assumptions.
Explore how a backup safety filter responds to moving obstacles hidden by occlusions.
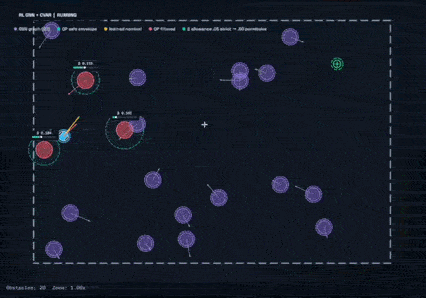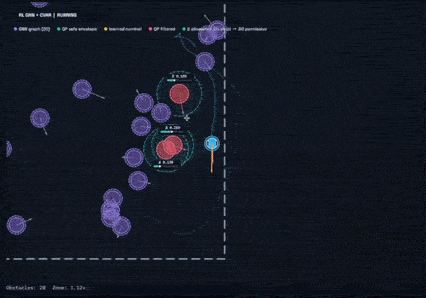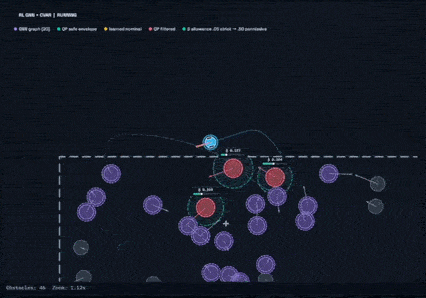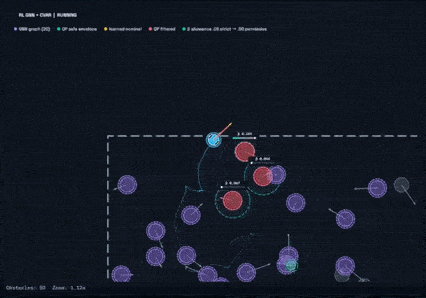
Explore learned risk adaptation and CVaR safety filtering for robot navigation in uncertain crowds.
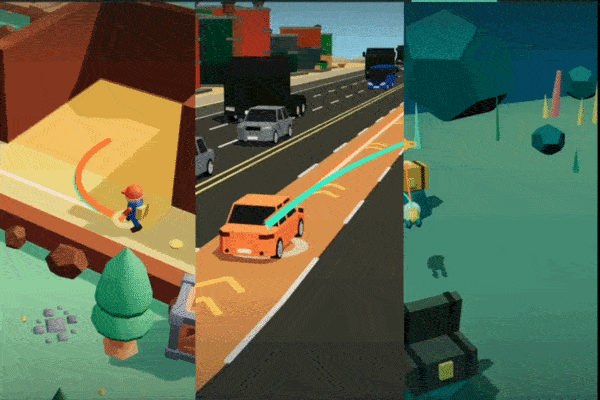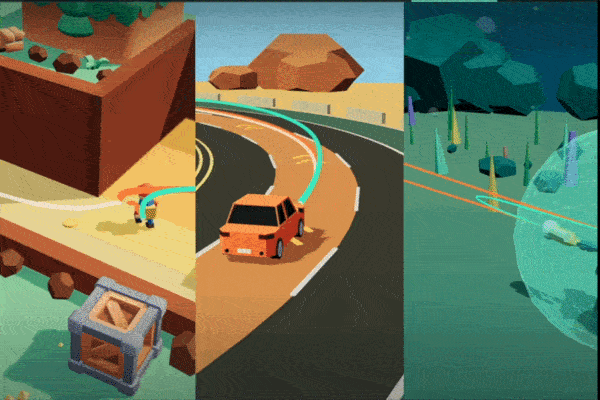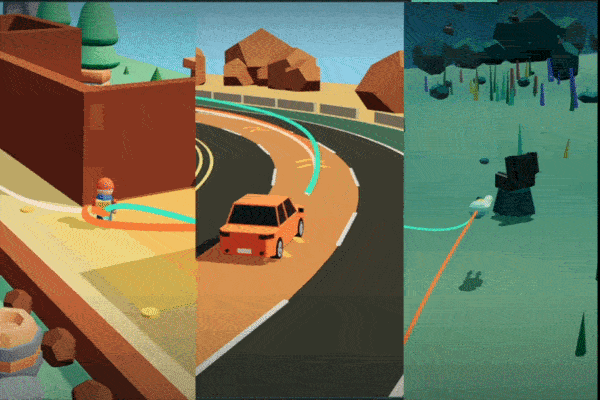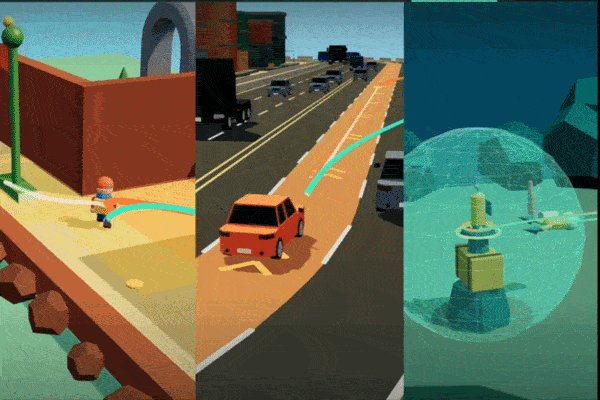
Compare Backup CBF, Model Predictive Shielding, and gatekeeper in interactive scenarios.
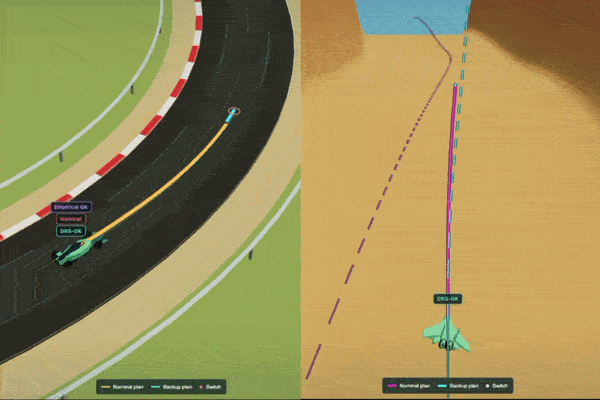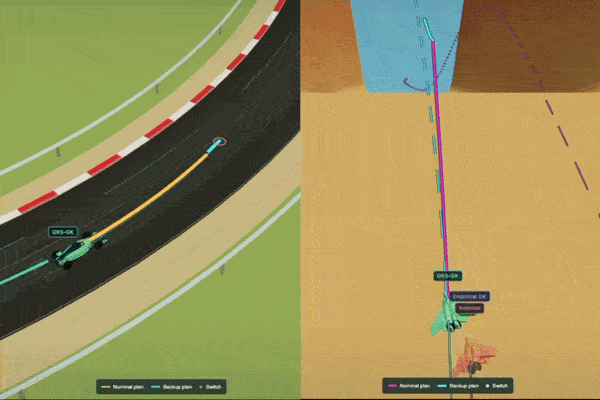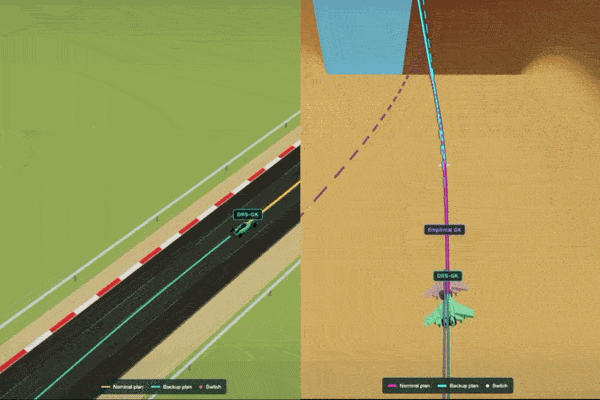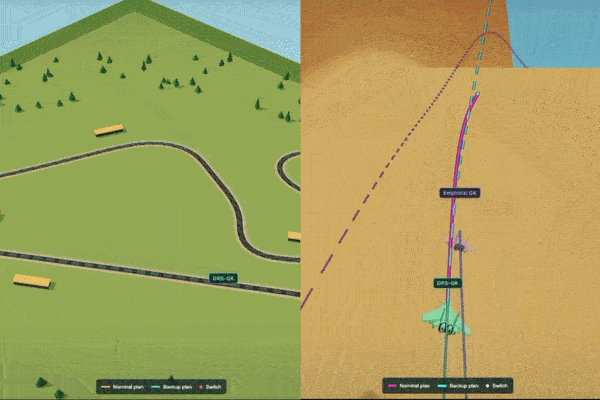
Explore how uncertainty and distributional robustness affect backup-based safety filtering.
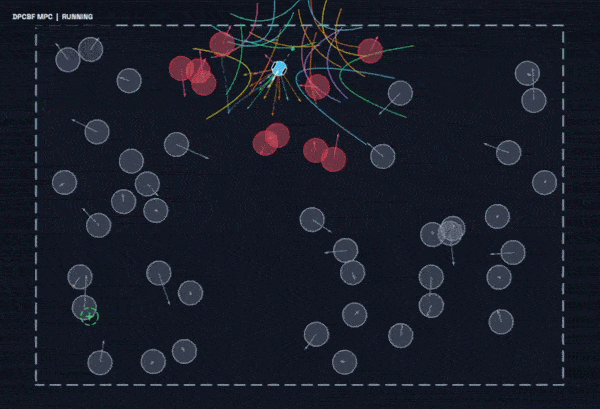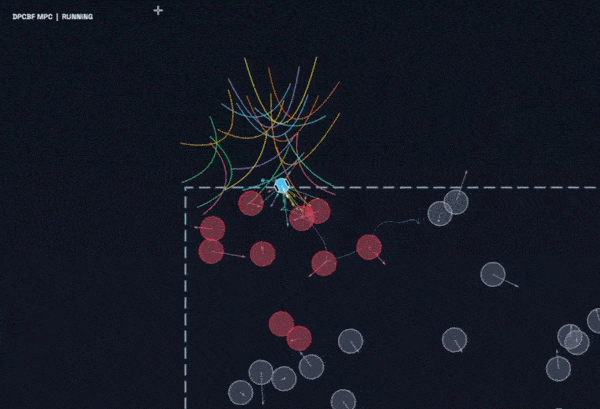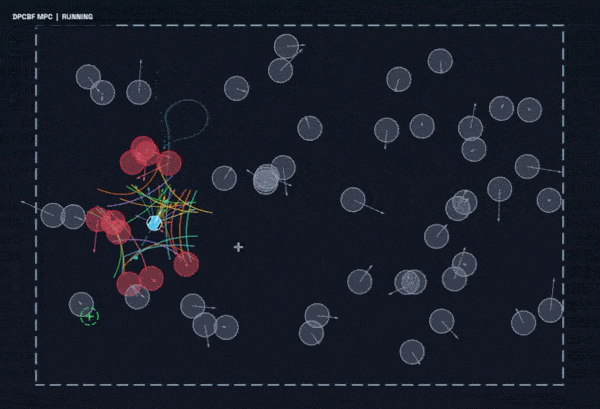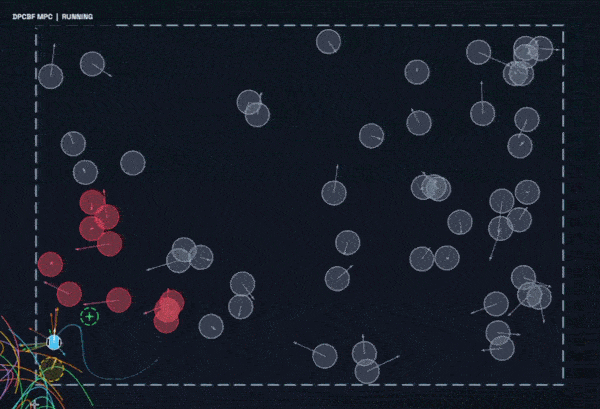
Explore dynamic obstacle avoidance with parabolic control barrier functions.
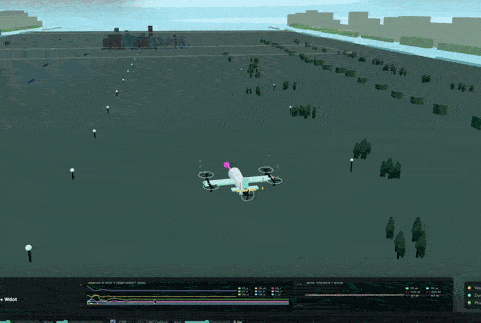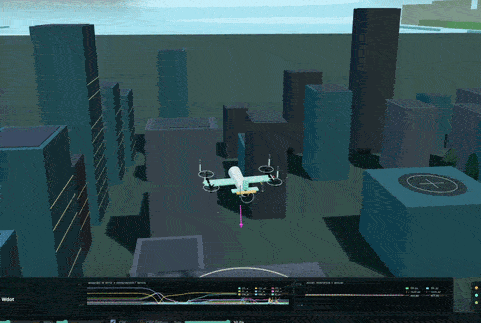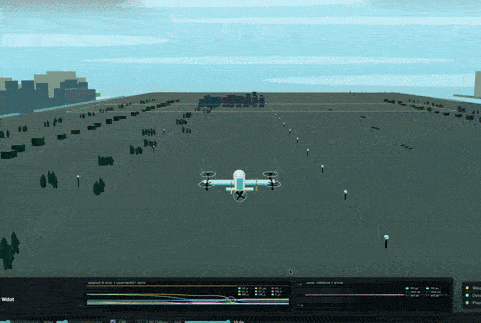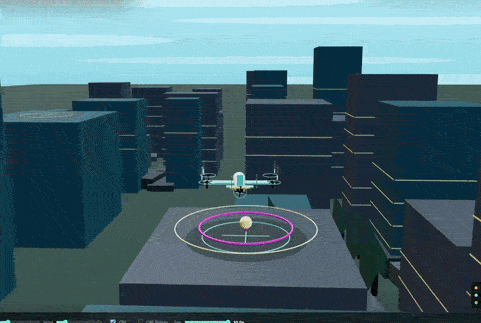
Explore safety-critical control during quadplane transition and landing maneuvers.
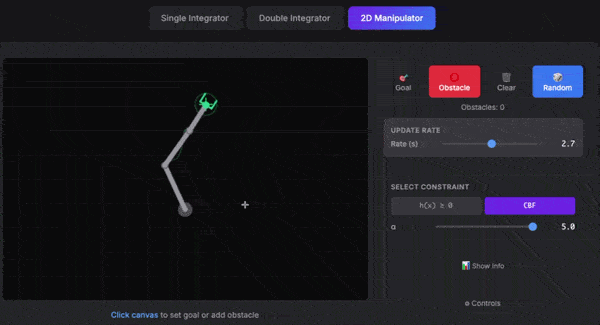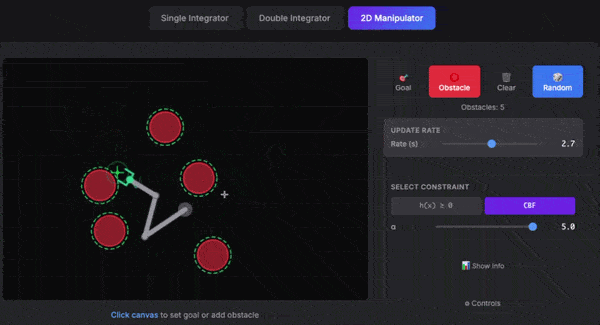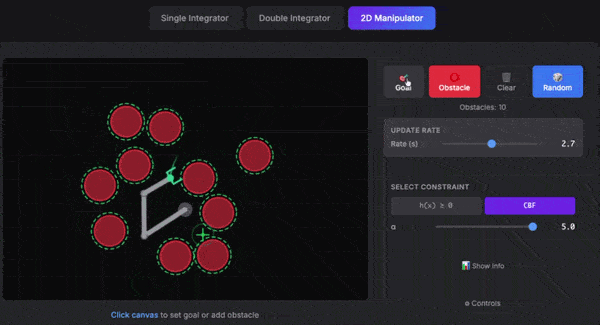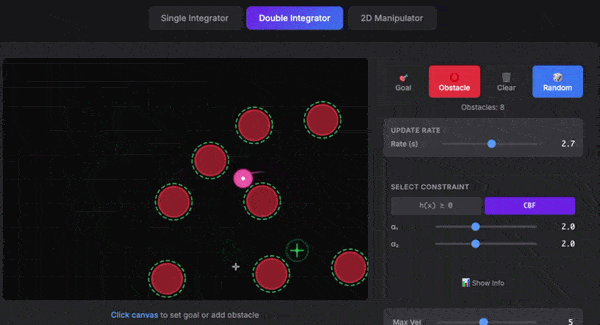
Experiment with control barrier functions and robot navigation directly in your browser.
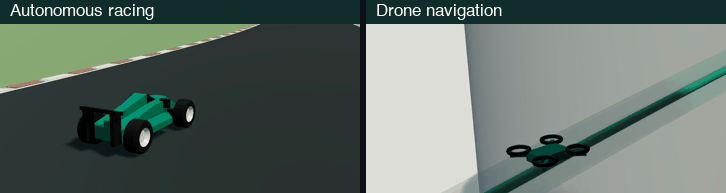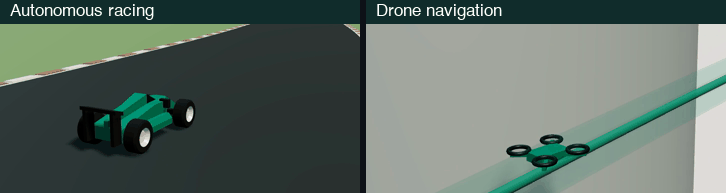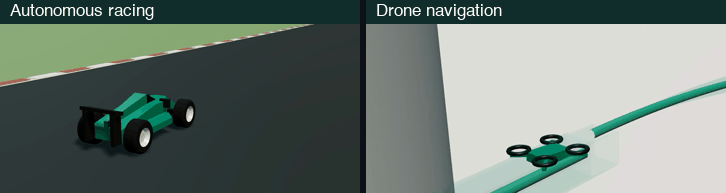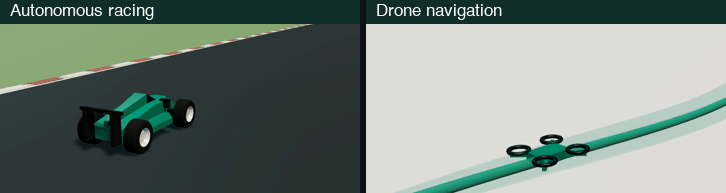
Explore how safe, budget-constrained active learning reduces tire-friction uncertainty during autonomous racing.
Explore how a quadrotor safely reduces aerodynamic-drag uncertainty while navigating obstacles under an exploration budget.